Perception · ROS 2 · 2026
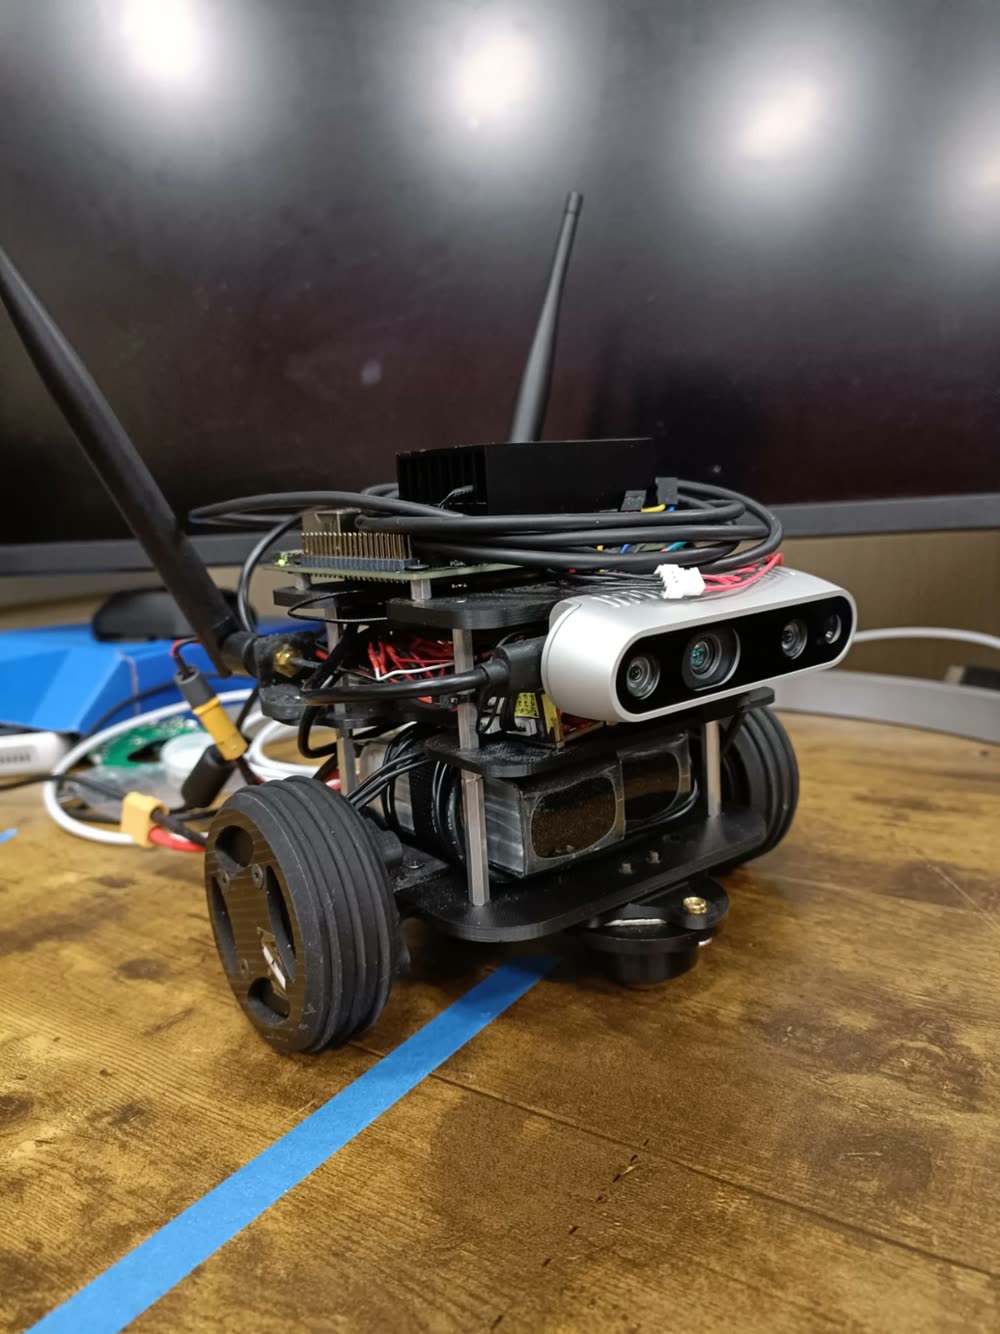
Autonomous robot: perception and SLAM.
Visual SLAM, EKF sensor fusion and YOLOv8 detection on a Jetson, on a robot I designed and built.
Open case studyDeelip Kumar Gummadidala, robotics engineer. I build perception and machine-learning pipelines for real robots, and design the mechanisms they run on.
Featured
Visual SLAM, EKF sensor fusion and YOLOv8 detection on a Jetson, on a robot I designed and built.
Open case studyinference per 640×480 frame
F1 predicting planner failures
occupancy map resolution
projects, from CAD to trained models
Index
Perception, machine learning and mechanical design, each built and tested on real hardware. Open any project for the details.
Films
Bench tests and demo days, playing silently on a loop.
About
I help robots understand where they are and what is around them. Visual SLAM, EKF sensor fusion and YOLO detection on a Jetson; models that predict when a planner will fail; and mechanisms I design in Fusion 360, 3D-print and test until they work.
Education & experience
Resume
Education, experience at 10Beauty and Segritech, projects and skills on a single page.
What I bring to a perception, ML or mechanical design team.
Contact
Open to roles in perception, computer vision, machine learning and mechanical design for robotics.